Lero.03
Autonomous field robot for bed cultivation
Lero.03 is a field robot for highly complex environments. It carries its implements over the beds on a robust bridge between two drive units, and is designed to work at least 8 hours a day. It changes implements on its own, maps and monitors the crop in 3D as it drives, and navigates safely even on uneven ground. From laser weeding and high-precision mechanical weeding to seeding and monitoring, it is built for everyday field work as much as for field trials and research.
Contact us for infos & data sheets!Lero.03 in action
-
01
Independent steering
Every wheel steers on its own. Lero.03 drives forwards, sideways or diagonally and turns on the spot, so it changes beds without a headland turn.
Lero.03 drives forwards, then sideways, then diagonally, and turns on the spot, each wheel steering on its own, while a plan view shows the angle of each wheel. -
02
Battery powered + solar panels
Lero.03 runs on batteries, and the solar panels on its roof extend its range per charge by up to 25%.
Sunlight sweeps over the solar panels on Lero.03's roof, while a bar fills with the range of one battery charge and then the up to 25% the solar panels add. -
03
360° perception
Two 3D lidars at opposite corners see all around the robot, while row cameras follow the crop rows.
Lero.03's two 3D lidars scan all around the robot while its row cameras look along the crop rows. -
04
Tool rails
Lero.03 swaps implements on its own: it parks one in a tool bay, moves sideways to the next and picks up another.
Lero.03 parks its weeder in tool bay A, moves sideways to bay C and picks up the laser weeder. -
05
One machine, multiple implements
With the laser weeder on, Lero.03 moves sideways onto the next bed and weeds between the rows.
With the laser weeder on, Lero.03 moves sideways onto the next bed and laser weeds between the crop rows.


How the Lero evolved
-
2022
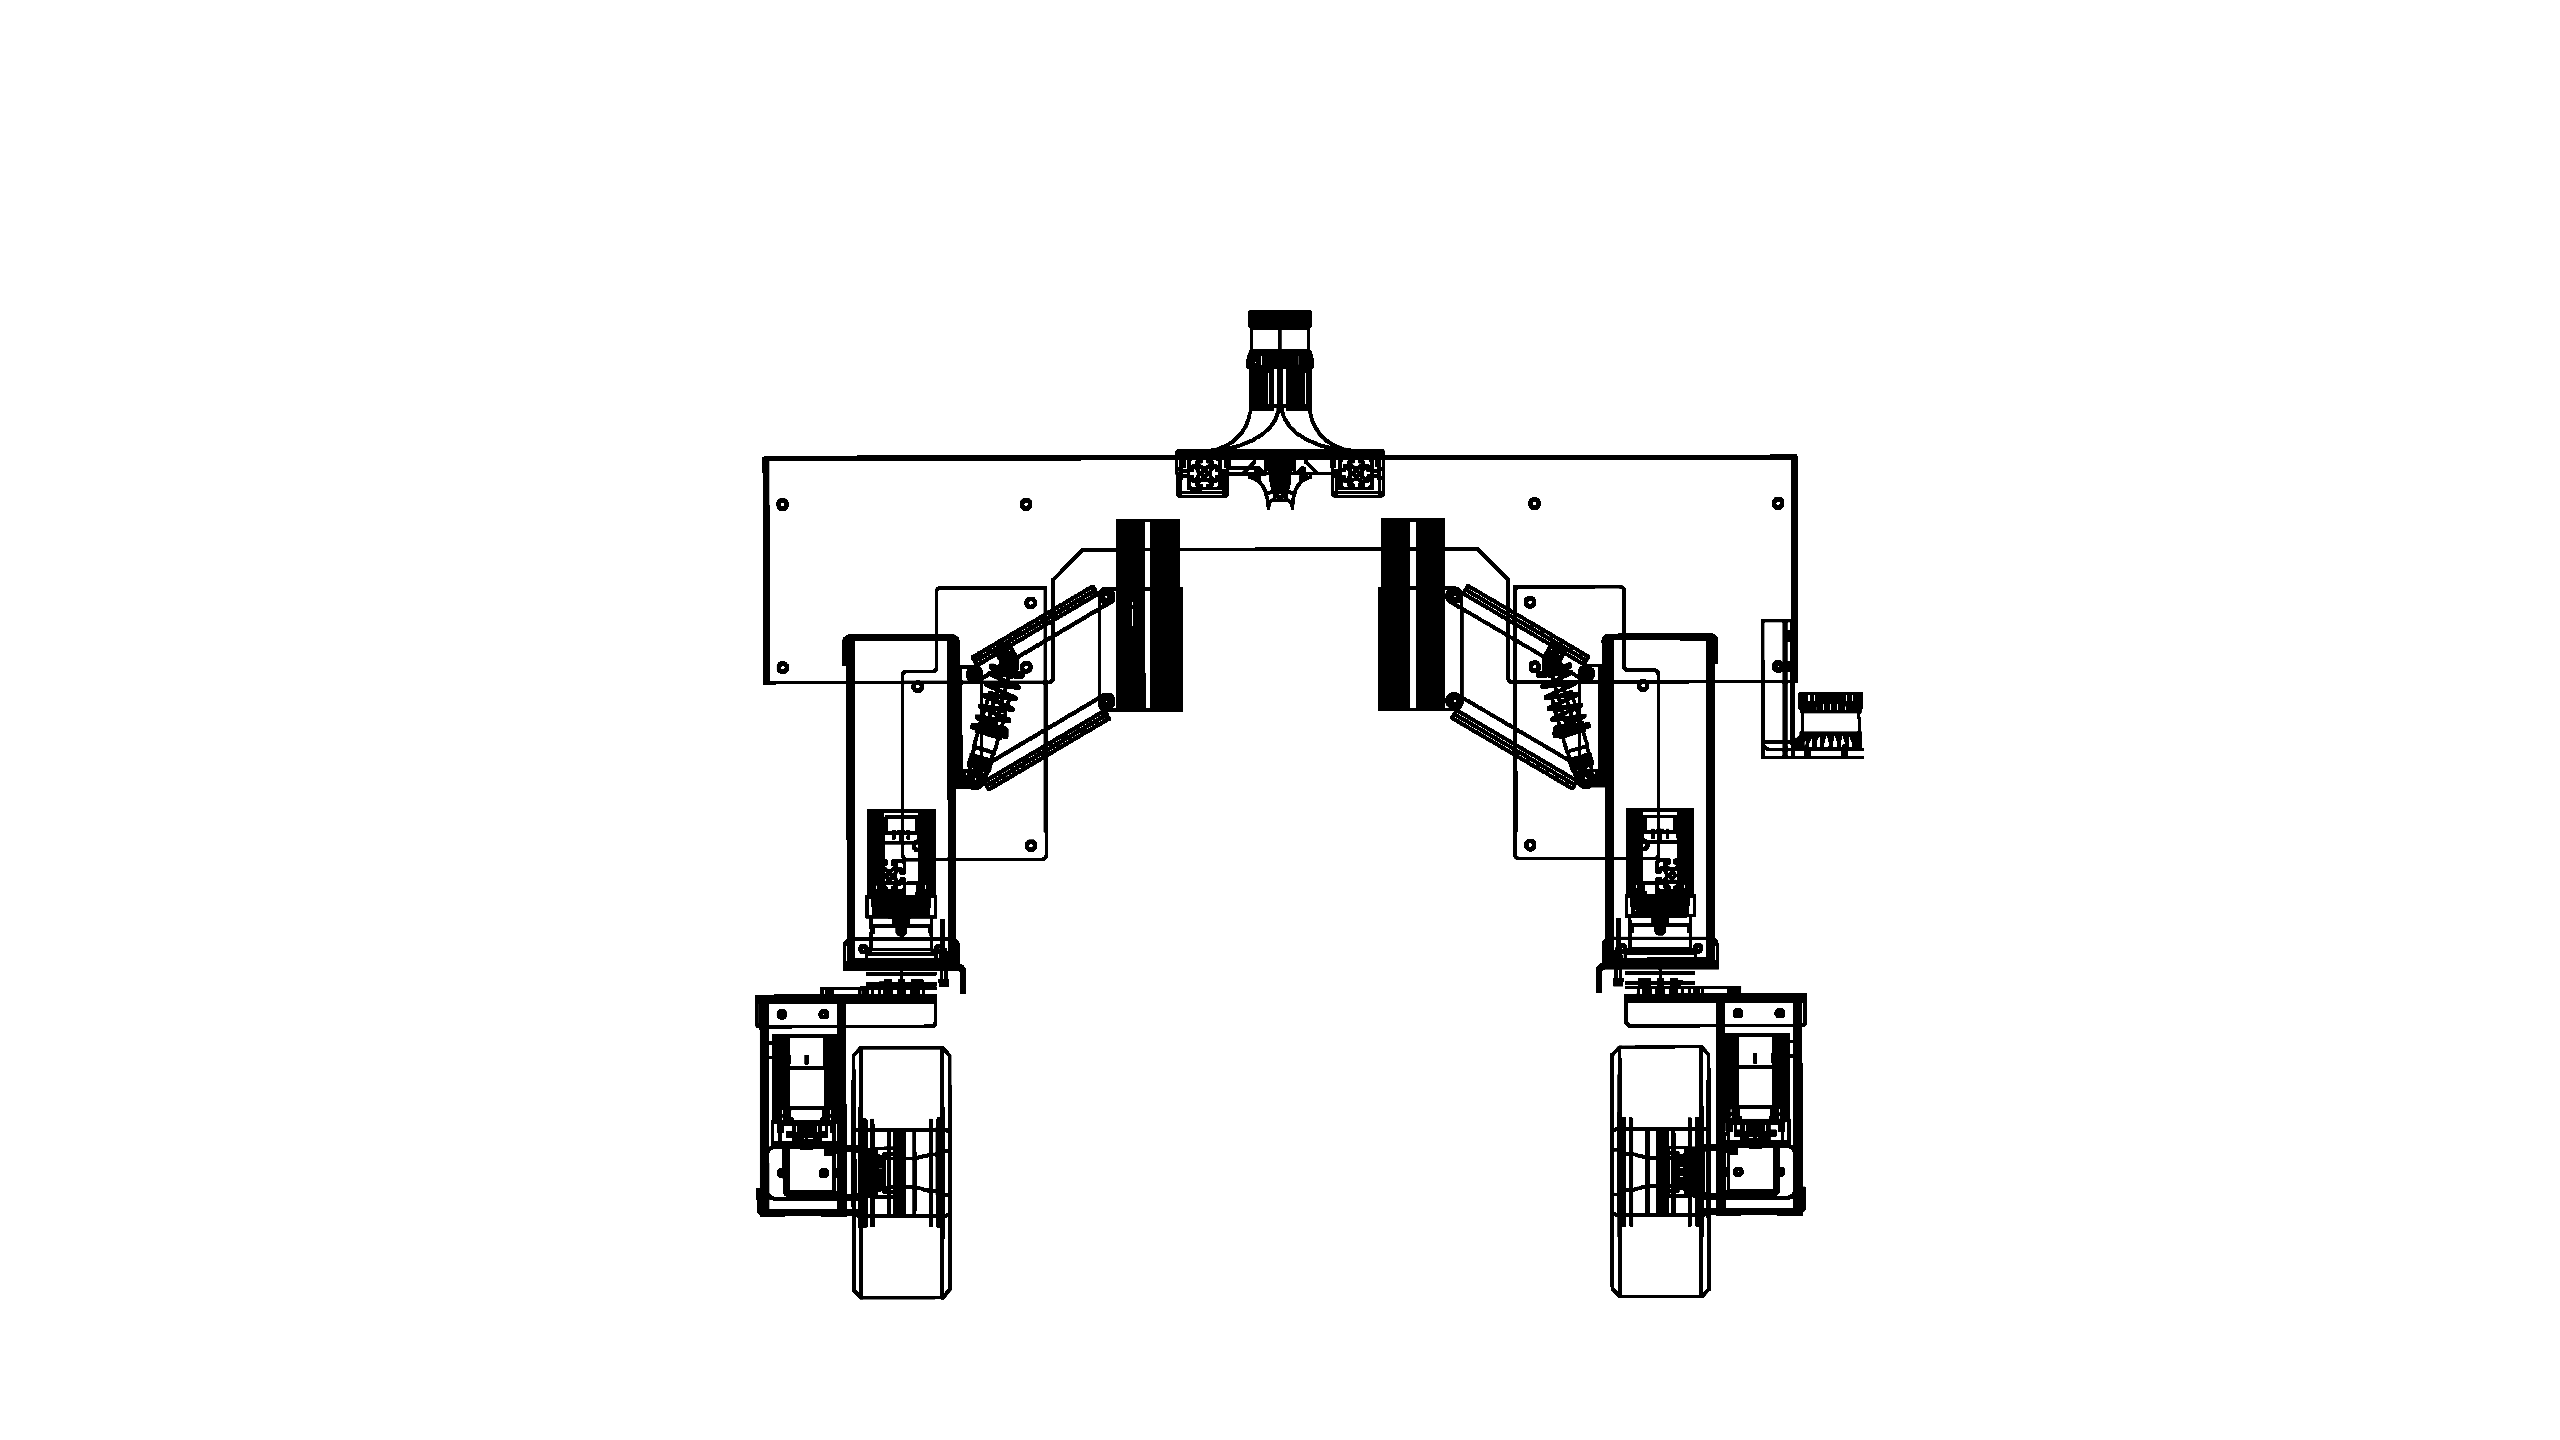
Lero.01
Navigation showcase and monitoring robot for 3D mapping and crop detection
The first prototype, built seven months into the EXIST Transfer of Research project.
-
2024
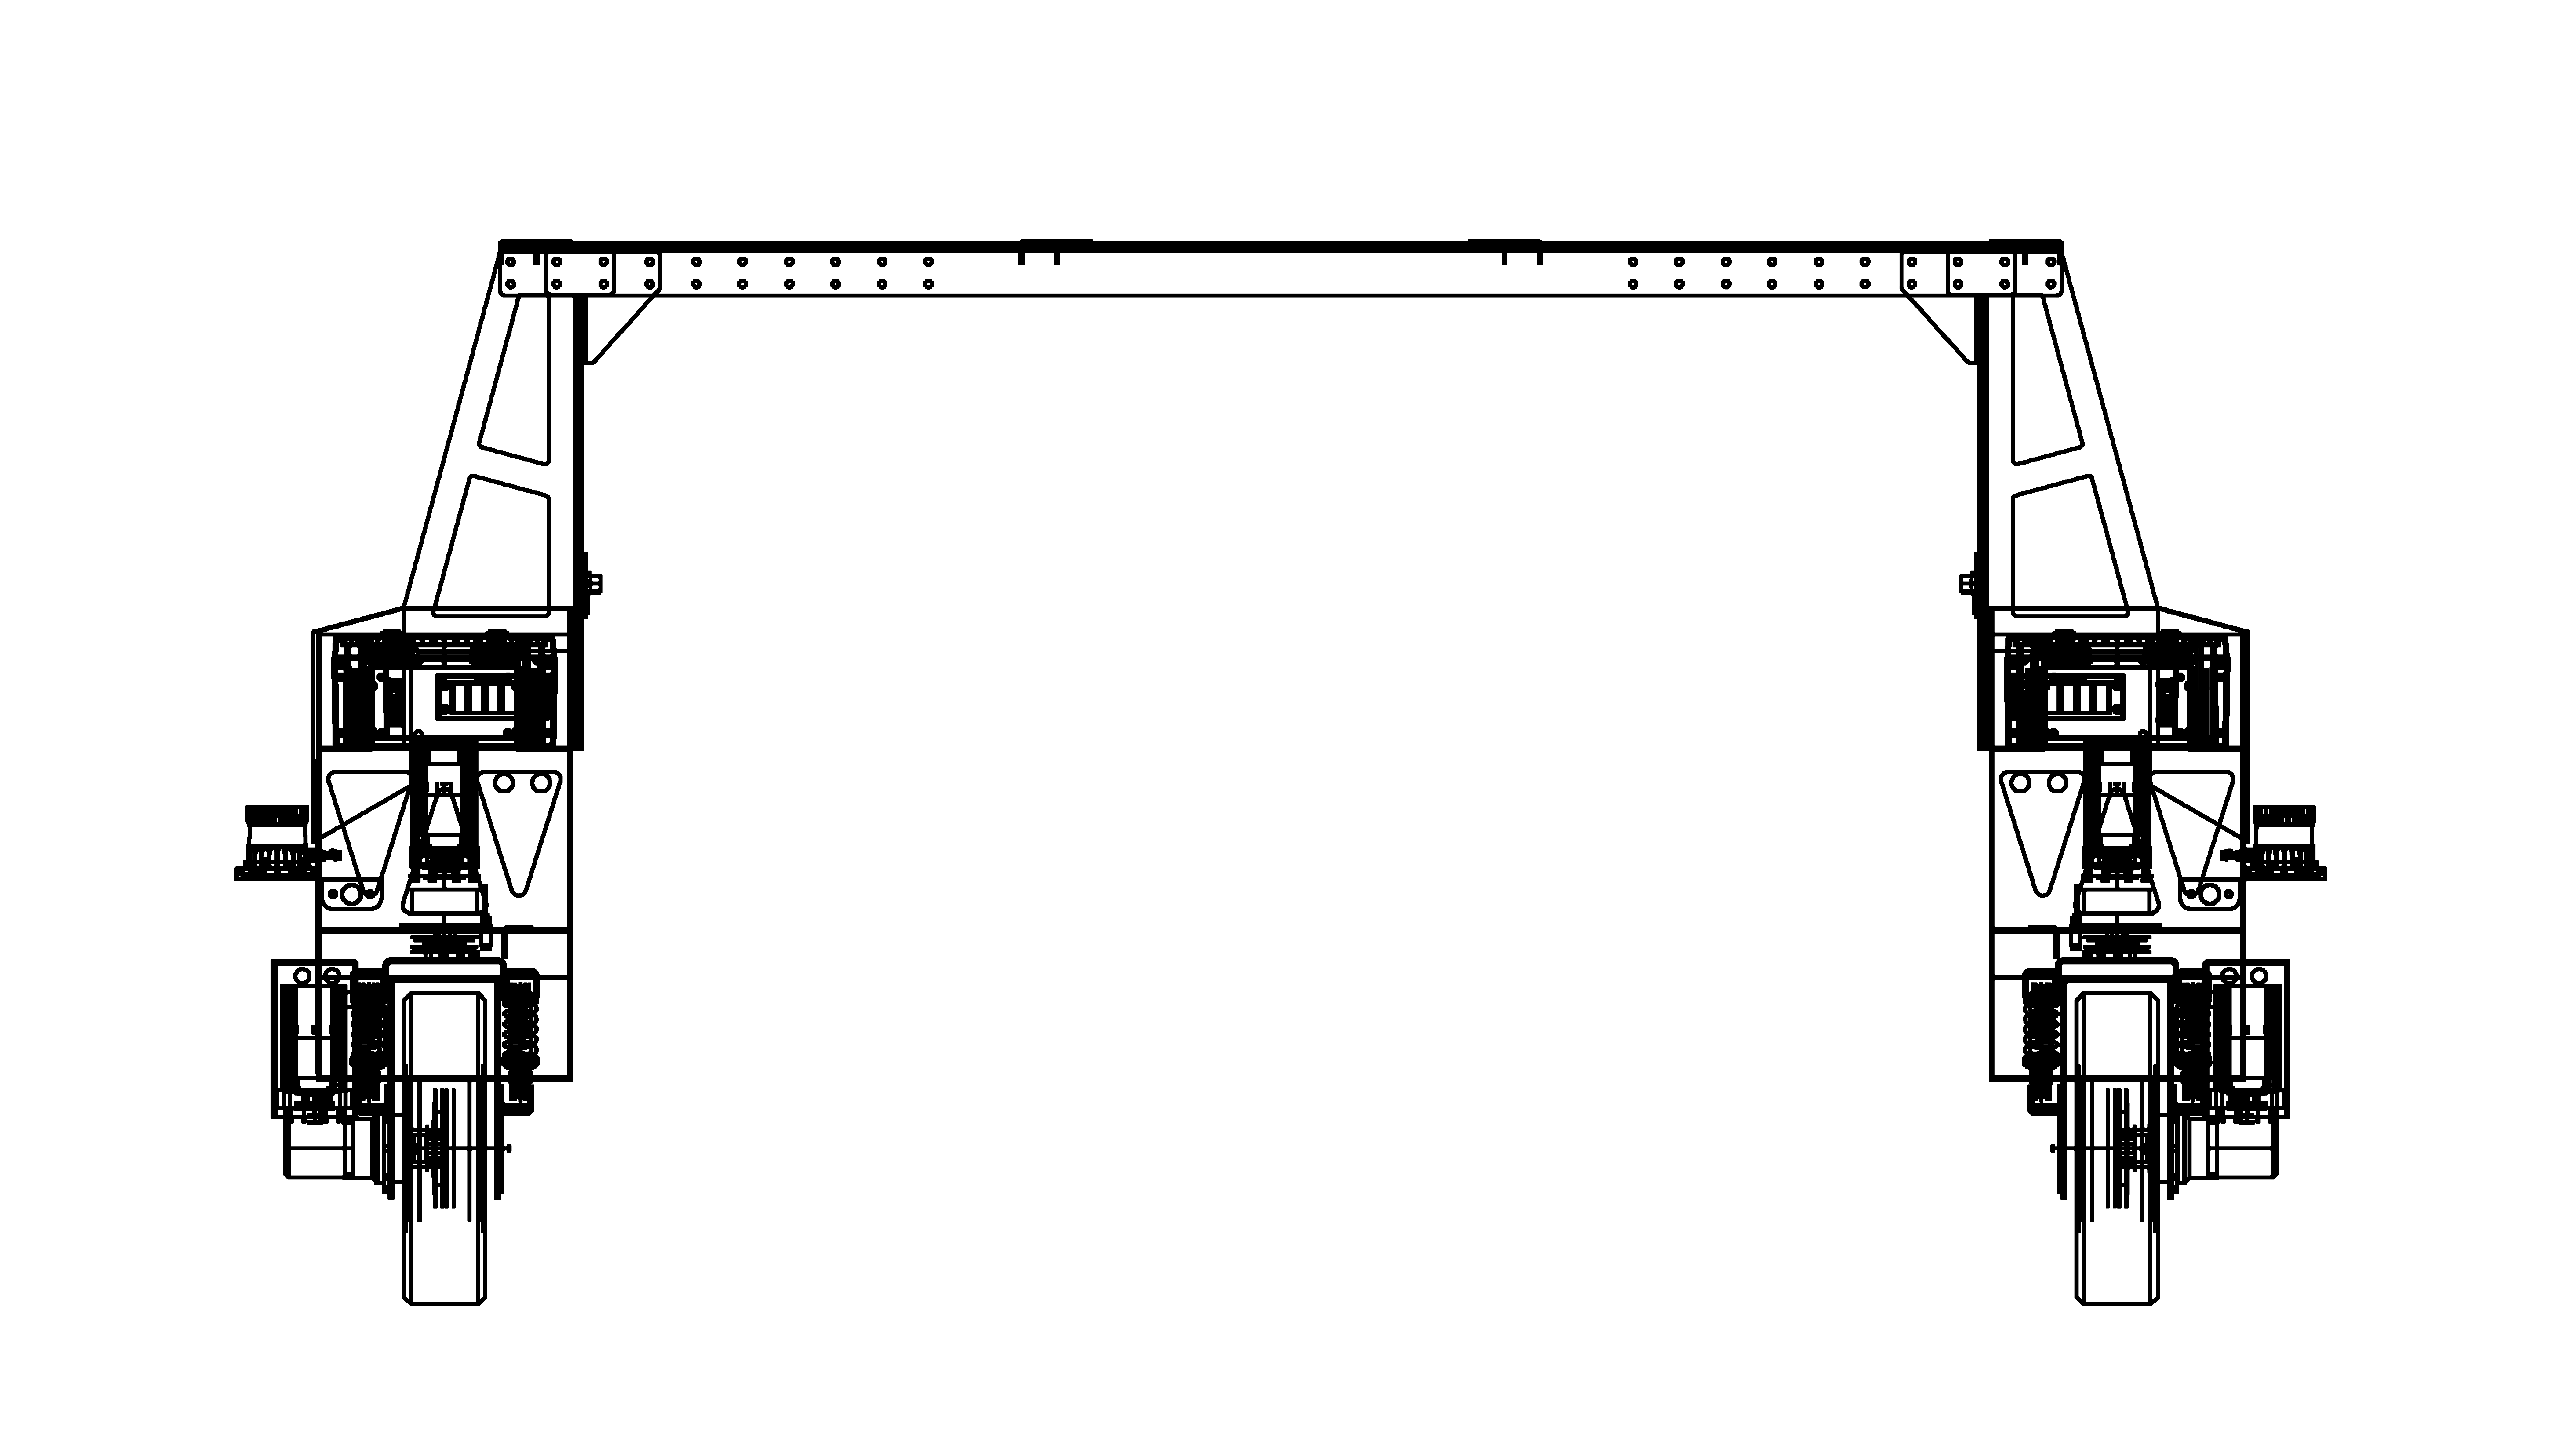
Lero.02
Advanced field robot for farming modules such as laser weeding
Considerably larger than its predecessor, carrying more payload and covering more ground per pass.
-
2025
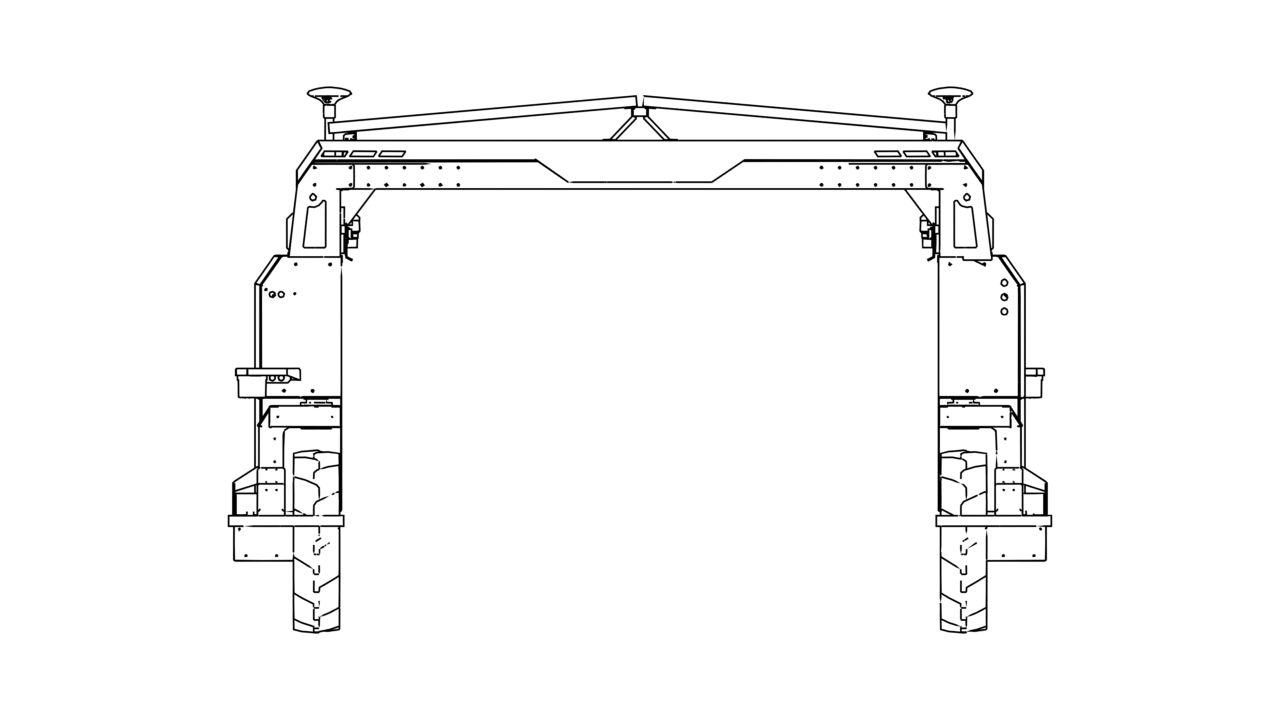
Lero.03
Highly modular and robust field robot
Field debut at our third Demo Day at Gut Arenshorst.