We Make Your Machines Autonomous
The autonomy OS for agricultural machinery manufacturers. No GNSS needed, any machine, any crop.
Discover Our SolutionsTurn conventional machinery into agricultural robots
Our hardware-agnostic FAOS retrofits onto your machine and has it driving autonomously as a proof of concept within four weeks.
Your machine always knows where it is. Hybrid localization fuses LiDAR and IMUs with GNSS and RTK when they are available, and keeps working wherever the signal gets too poor to use.
Explore Hybrid LocalizationMap your field once and the FAOS plans how to cover it row by row, leaving out the areas and obstacles you mark.
Explore Field Coverage & Row PlanningAt the end of each row the FAOS plans a turn that fits your machine and the headland, from a wide U-turn to a multi-point turn where space is tight.
Explore Smart Turn PlanningThe FAOS keeps your machine precisely on its line along every row and steers it smoothly at the speed the job needs.
Explore Row Following & Motion Control3D sensors watch the path ahead. When a person, animal or object is in the way, your machine slows down, stops or drives around it.
Explore Environment Perception & Obstacle AvoidanceAn operator can follow the machine live from anywhere and step in when needed, the way the EU AI Act asks for human oversight.
Explore Remote Human OversightPick a feature on the wheel to explore it
Compliant by design: a deterministic low-level security kernel underneath keeps your machine aligned with European standards, including the CRA, AI Act and Data Act.
Reliable where it counts: hybrid localization fuses LiDAR and IMUs with GNSS, so your machine keeps working under tree canopies, inside barns and warehouses and wherever GNSS gets too poor to use.
Hybrid Localization with(out) GNSS & RTK
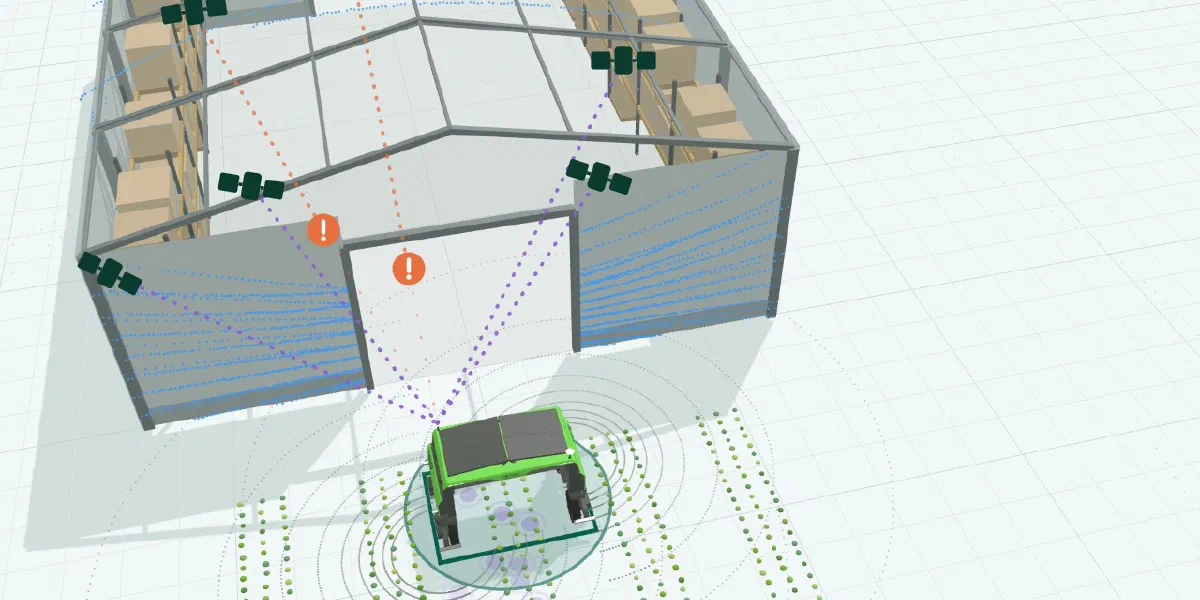
Your machine always knows where it is. Hybrid localization fuses LiDAR and IMUs with GNSS and RTK when they are available, and keeps working wherever the signal gets too poor to use.
Explore Hybrid LocalizationField Coverage & Row Planning
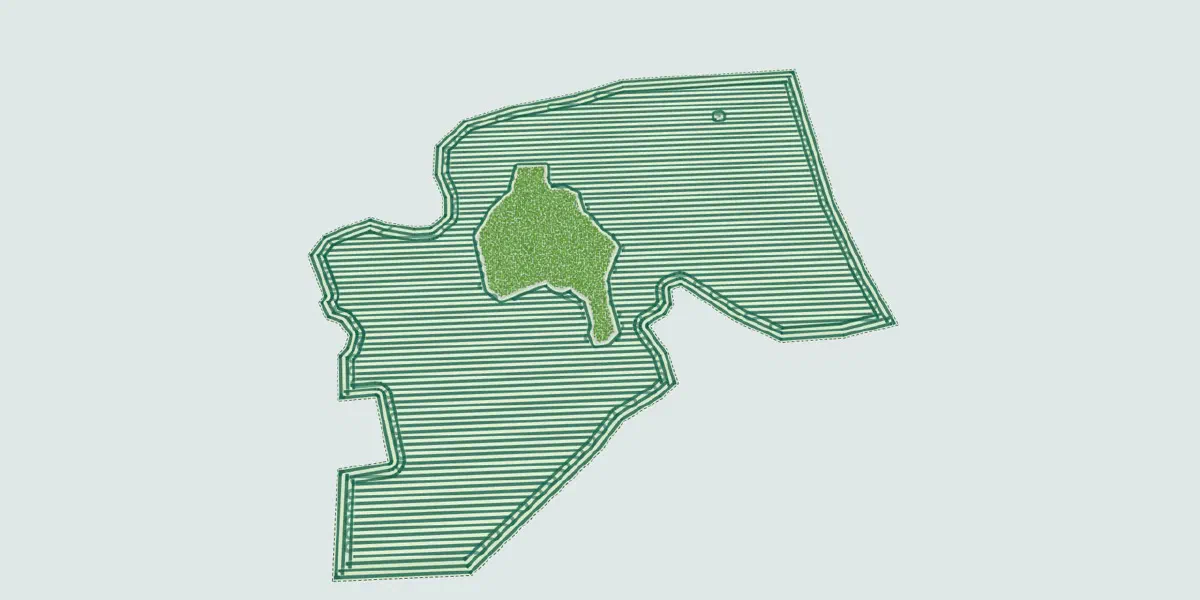
Map your field once and the FAOS plans how to cover it row by row, leaving out the areas and obstacles you mark.
Explore Field Coverage & Row PlanningSmart Turn Planning
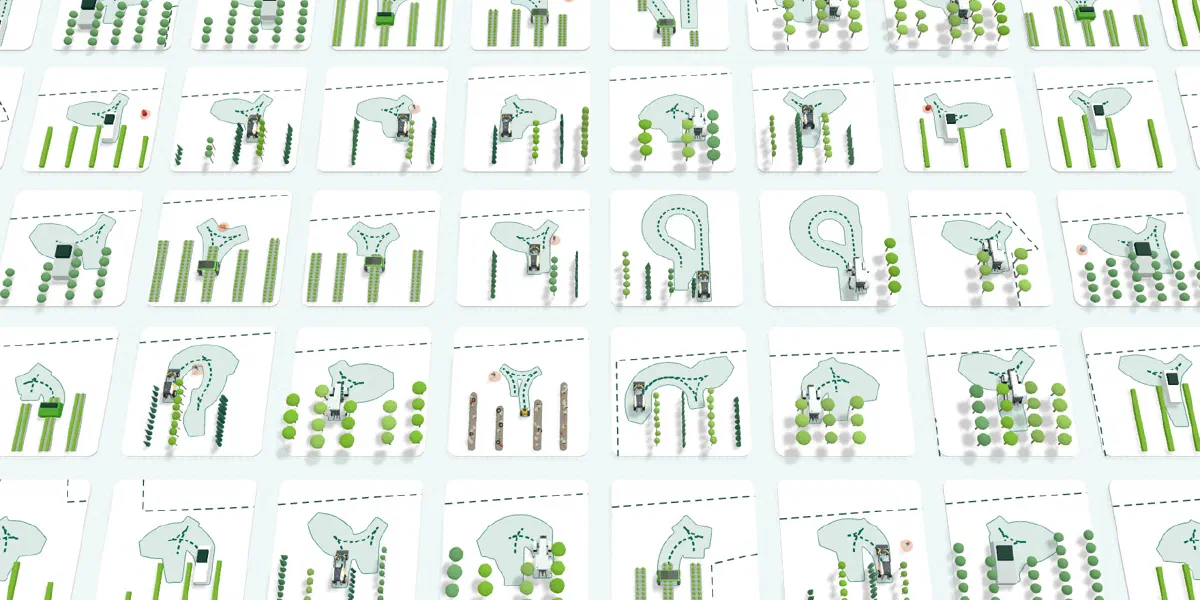
At the end of each row the FAOS plans a turn that fits your machine and the headland, from a wide U-turn to a multi-point turn where space is tight.
Explore Smart Turn PlanningRow Following & Motion Control
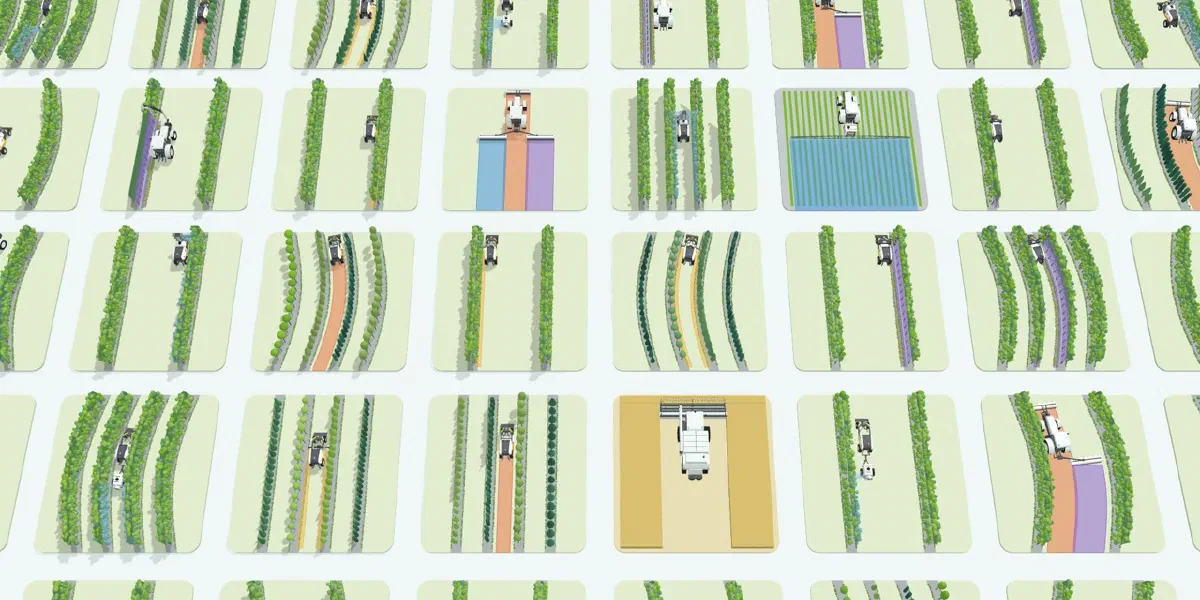
The FAOS keeps your machine precisely on its line along every row and steers it smoothly at the speed the job needs.
Explore Row Following & Motion ControlEnvironment Perception & Obstacle Avoidance
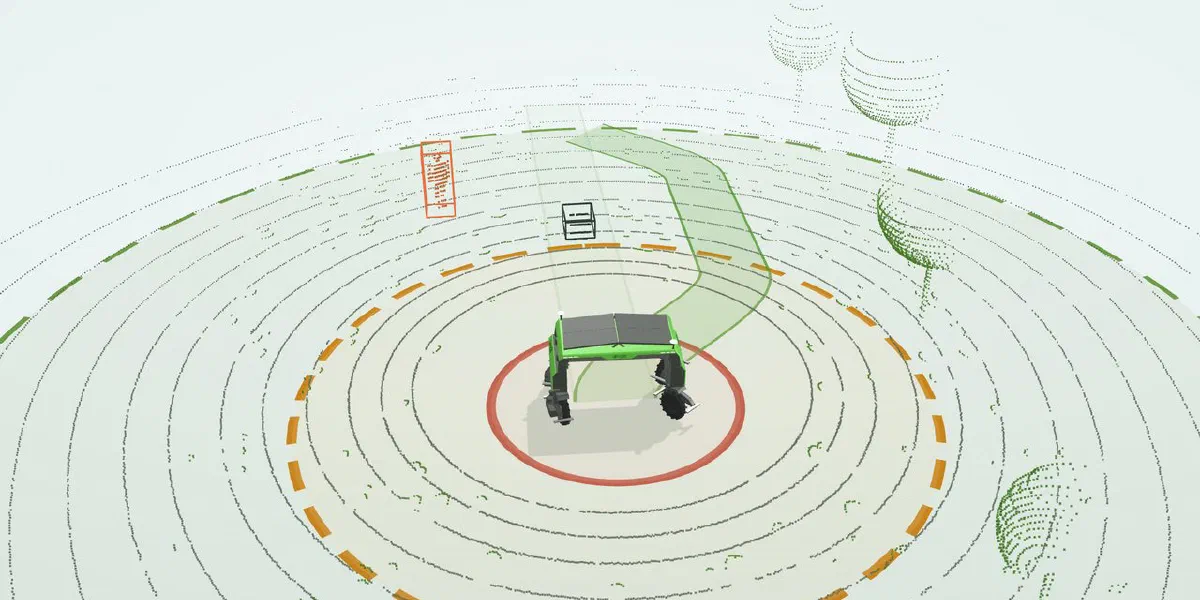
3D sensors watch the path ahead. When a person, animal or object is in the way, your machine slows down, stops or drives around it.
Explore Environment Perception & Obstacle AvoidanceRemote Human Oversight
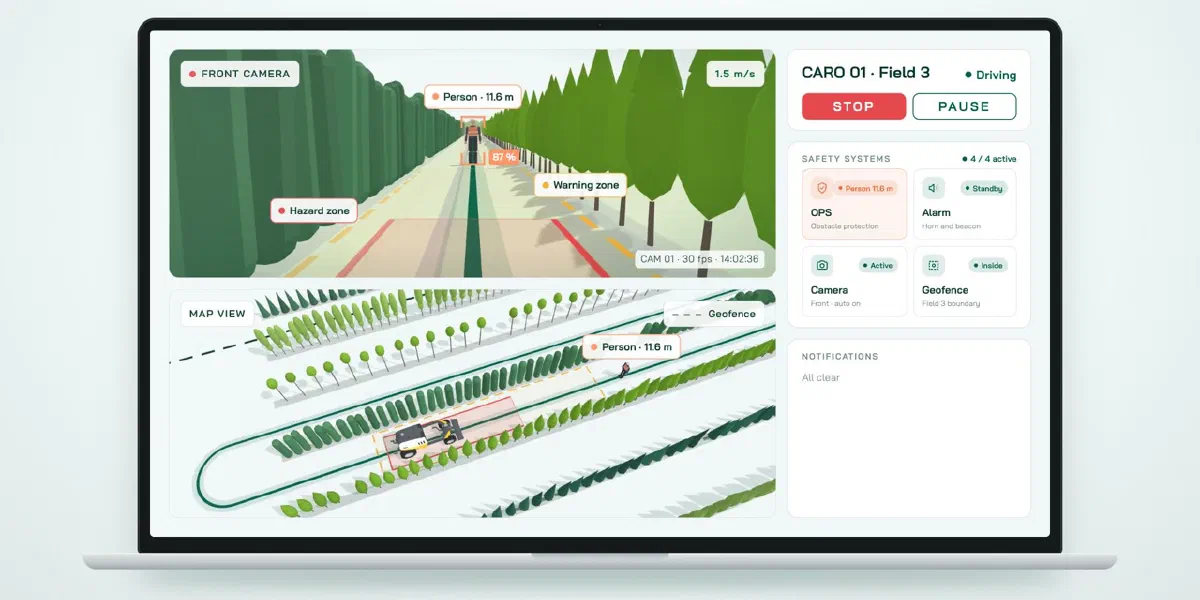
An operator can follow the machine live from anywhere and step in when needed, the way the EU AI Act asks for human oversight.
Explore Remote Human OversightCurious how it fits your machine? Get in touch with our team to talk through your use case.
Go AutonomousThe Mission Control in Action
Explore how an operator sees the Nature Robots mission control functions - from defining the field boundaries to planning complex missions on a field.
Map Your Field
Transform field boundaries and operational parameters into a trajectory for an autonomous robot.
Create the Mission
Generate multiple beds within one field and assign mission-specific row parameters to them.
Complete the Mission
Manually connect beds, add waypoints and select specific tasks for your rows.
Mission Control Overview
Get a brief overview of the three mission control features.
Our Ready-to-Use
Farming Autonomy OS
We enable navigation in environments where conventional approaches fail — even in GNSS-denied areas. Choose the solution that unlocks unimagined efficiency and scalability.
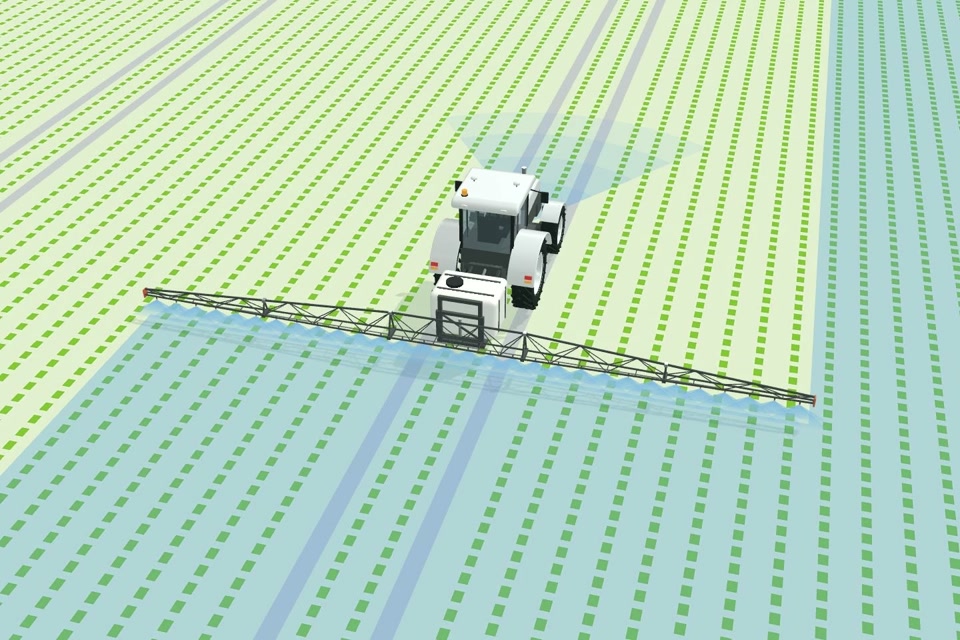
OpenField Nav
Optimized for open fields e.g. plowing, seeding, or harvesting.
Cereal & Grain Fields
Legume & Pulse Fields
Grasslands & Pastures
Oilseed Crop Field
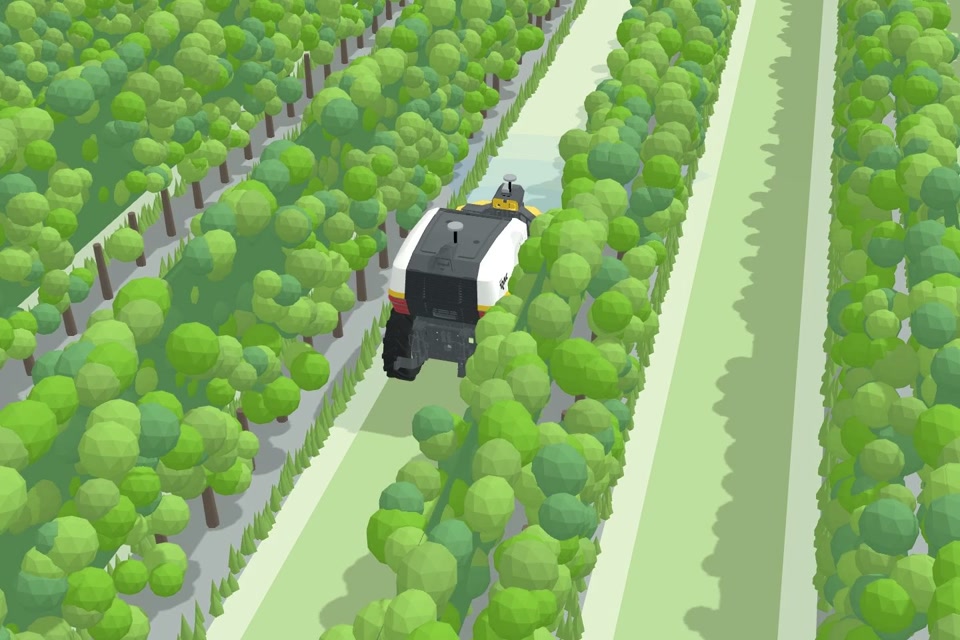
OrchVine Nav
Optimized for perennial farming with row structures for e.g. spraying.
Orchards
Vineyards
Hops
Agroforestry
Agri-PV
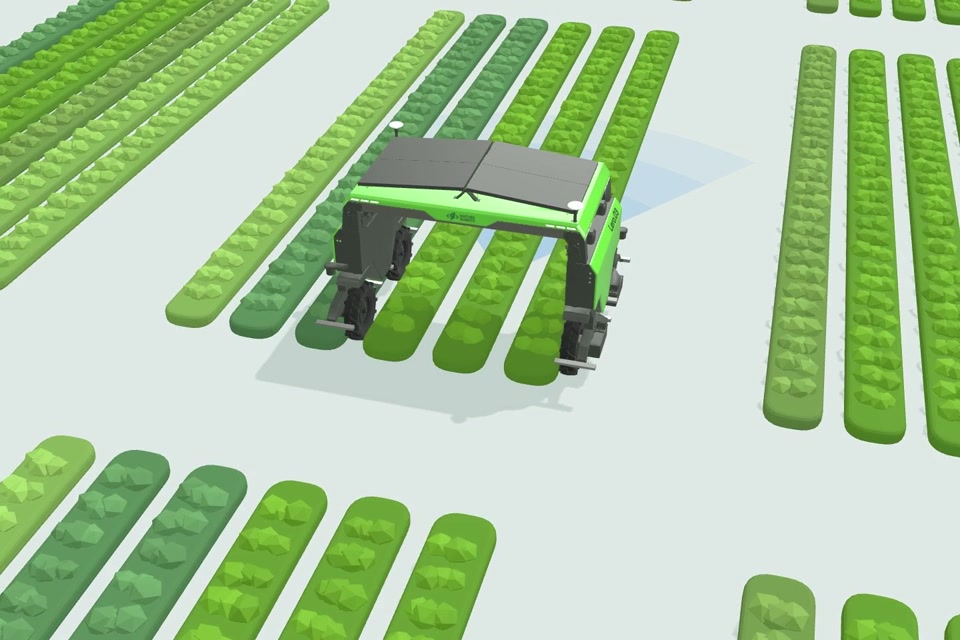
Horti Nav
Optimized for plot-based environments and controlled traffic farming.
Vegetable Production
Market Gardening
Breeding Parcels
Greenhouses
From Prototype
to Series Production
Proof of concept completed after four weeks - followed by a clear path to a certified series product.
Pilot autonomy within four weeks
-
Application Design
01- Farming Specifications
- Technical Specifications
- Product Configuration
-
Modelling & Configuration
02- Hardware Abstraction Layer
- URDF & Digital Twin
- Use Case Simulation
-
Machine in the Field
03- On-Site Deployment
- First Autonomous Run
- Handover & Training
The reliable way to production
-
Safety & Compliance
04- Risk Assessment
- Safety & Compliance Strategy
- Certification Readiness
-
Field Validation
05- Edge-Case Reliability
- Performance Monitoring
- Regulatory Verification
-
Series Operation
06- Remote Monitoring
- Over the Air Updates
- Legal Tracking